ROS 2 Relocalization for an Autonomous Robot-Vacuum Maker
Coverage cleaning and kidnapped-robot recovery for an open-source robot vacuum, on ROS 2.
A ROS 2 Jazzy / Nav2 milestone: a boustrophedon coverage planner and kidnapped-robot recovery, validated by headless regression suites.
- Boustrophedon coverage planner on ROS 2 Jazzy / Nav2
- Kidnapped-robot recovery via relocalization
- Headless Gazebo regression suites for reproducible acceptance
- Measured: ~90% coverage, ~87% path efficiency, 10/10 relocalize at ~6s / <=0.12m
A milestone engagement for a maker of open-source autonomous robot vacuums. The work delivered two behaviours on ROS 2 Jazzy with Nav2 and Gazebo: a boustrophedon coverage planner that sweeps a room efficiently, and a kidnapped-robot recovery routine that relocalizes the robot after it is picked up and moved. Both were validated by headless regression suites so results are reproducible in CI, not just on a demo run.
The measured outcomes from the regression harness: roughly 90% area coverage, about 87% path efficiency, and 10 out of 10 successful relocalizations averaging six seconds at sub-0.12-metre accuracy. Beyond trading automation, this demonstrates real robotics and systems-engineering range: navigation stacks, simulation, and metric-driven acceptance testing. Client name withheld under the engagement. Reporting the numbers straight from the regression harness, rather than a hand-picked demo run, is what makes the milestone defensible, and the headless suites mean anyone can reproduce those figures in CI.
How it works
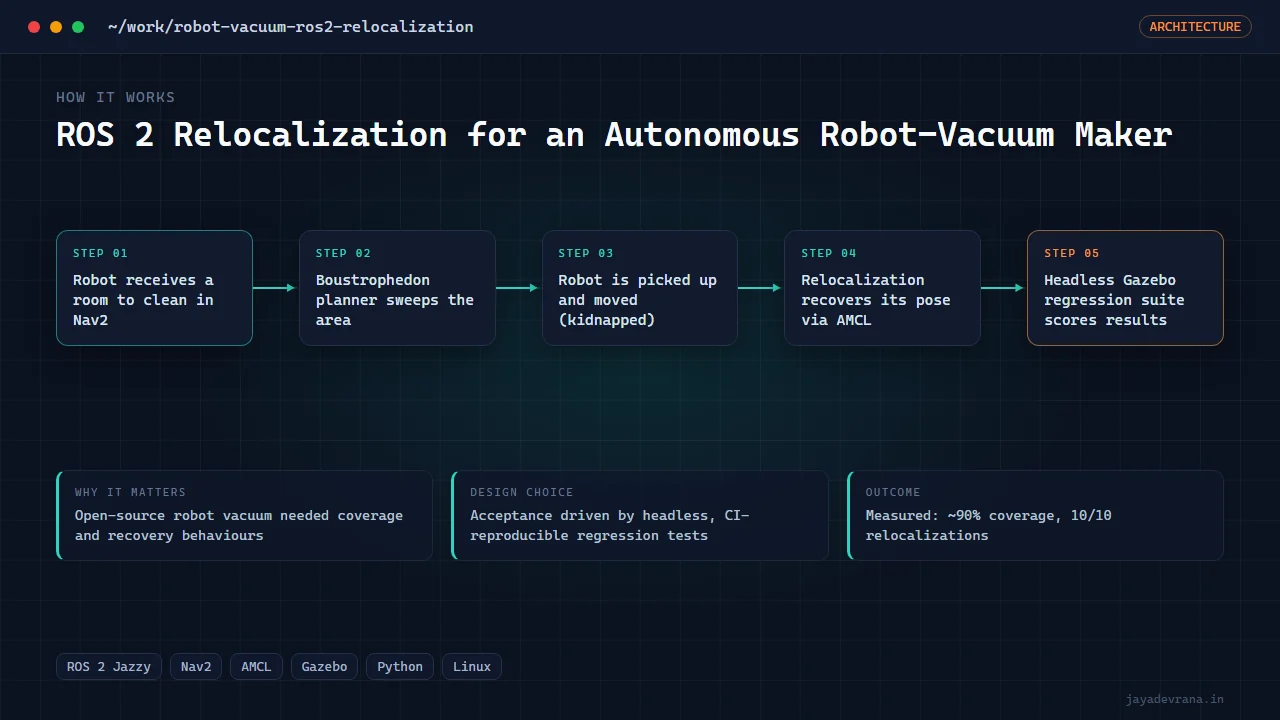
- Robot receives a room to clean in Nav2
- Boustrophedon planner sweeps the area
- Robot is picked up and moved (kidnapped)
- Relocalization recovers its pose via AMCL
- Headless Gazebo regression suite scores results